
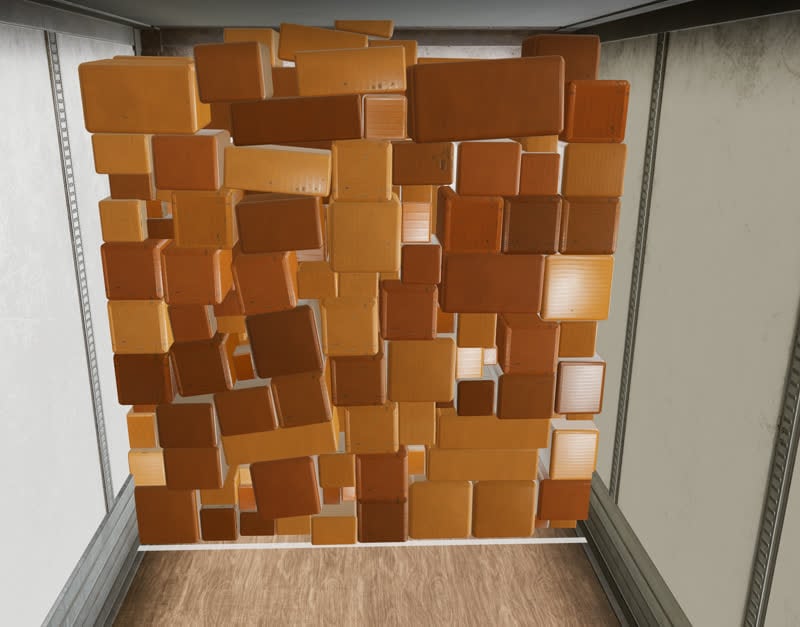
This is just one of the problems Foresight solves. Spatial packing is one dimension of a much broader system. In production, Foresight simultaneously reasons about physical stability to prevent wall collapses, incorporates robot motion and reachability constraints, trades off density goals against dual-arm parallelism for higher throughput, imagines how packages will shift under gripper forces, and handles uncertainty in box dimensions and rigidity to produce robust placements. Each of these is a hard problem on its own. Composing them into a coherent, real-time system is where most approaches fail.
3. Capability-aware orchestration: Dexterity deploys teams of specialized skill agents: perception, motion planning, grasp selection, force control. What makes orchestration capability-aware is the world model underneath it. Foresight does not just model the state of the environment. It models the feasibility of every action in that state: whether a grasp will hold, whether a path is clear, whether a placement will remain stable. The orchestrator does not need its own understanding of physics. Foresight gives it one.
2. Pragmatic decision-making: In production, globally optimal placement is rarely achievable. Time pressure, imperfect sensing, and an unpredictable object sequence define the operating reality. Foresight provides rich enough state prediction that algorithms can evaluate the tradeoff between optimal and good-enough, because it can simulate the downstream consequences of both. Knowing when good enough is the right answer separates systems that work in demonstrations from systems that work in production.
Packing a truck is one of the hardest spatial reasoning challenges in Physical AI. The problem presents a constrained three-dimensional volume. Boxes arrive in random sizes, weights, and order. The objective is to maximize density while maintaining stability: walls of boxes that will not collapse, weight distributed safely, fragile items protected. All of this must be accomplished at production speed, with no advance knowledge of what is coming next.
1. Predictive branching: Foresight can roll the world state forward under hypothetical actions, simulating the consequences of each candidate placement before anything moves. This gives planners the ability to explore multiple futures, score them against physics constraints, and reject commitments the system cannot recover from. The branching algorithm is replaceable. The world model that makes branching meaningful is not.
Foresight is built as an operator, not a database. It transforms the current physical state of the world into an updated state at each timestep, integrating multi-modal sensor data, robot body state, and the outcomes of physical interactions. Every update maintains explicit uncertainty bounds, physics constraints, and rollback capability. Every decision the system makes can be traced, inspected, and understood.
On average, Foresight’s packing agent makes a placement decision in under 400 milliseconds, while simultaneously optimizing for density, physical stability, robot reachability, and dual-arm parallelism. Most academic packing solvers optimize a single objective and take orders of magnitude longer. Foresight optimizes all of them jointly, in real time, on sequences it has never seen before.
Manipulation demands a fundamentally different kind of understanding. When a robot picks up a box, the world changes. Objects shift. Previously hidden surfaces become visible. Stability conditions evolve. The world model must not only perceive these changes: it must predict them before they happen, reason about them as they unfold, and update its beliefs based on what actually occurred.
Speed matters because logistics does not wait. A truck loading dock has a schedule. A fulfillment center has throughput targets. A robot that thinks carefully but acts slowly is a robot that gets replaced by a human. Foresight is built to be both safe and performant, because in production these properties are not optional and cannot be traded off against each other.
Getting beyond that is where it gets interesting. The combinatorial space explodes. Every placement constrains every future placement. A locally optimal choice can lead to a globally suboptimal outcome. All of this must be navigated under time pressure, with imperfect information, in a sequence that cannot be controlled.
官网:https://dexterity.ai/blog/foresight
资料来源:企业官网公司介绍页面(复核日期:2026-10-29)。